Menu

1 / 4

Unveiled at ROSCon: the easiest way to bring Arduino I/O into ROS 2 | Arduino Blog

#arduino#microcontroller#running#linux#real
Reading 0:00
15s threshold

If you’ve ever built a robot with ROS 2, you know the classic architectural split: a powerful computer running Linux handles high-level navigation, mapping, and planning, while an external microcontroller handles the deterministic, real-time job of toggling GPIOs, reading sensors, and driving motors.

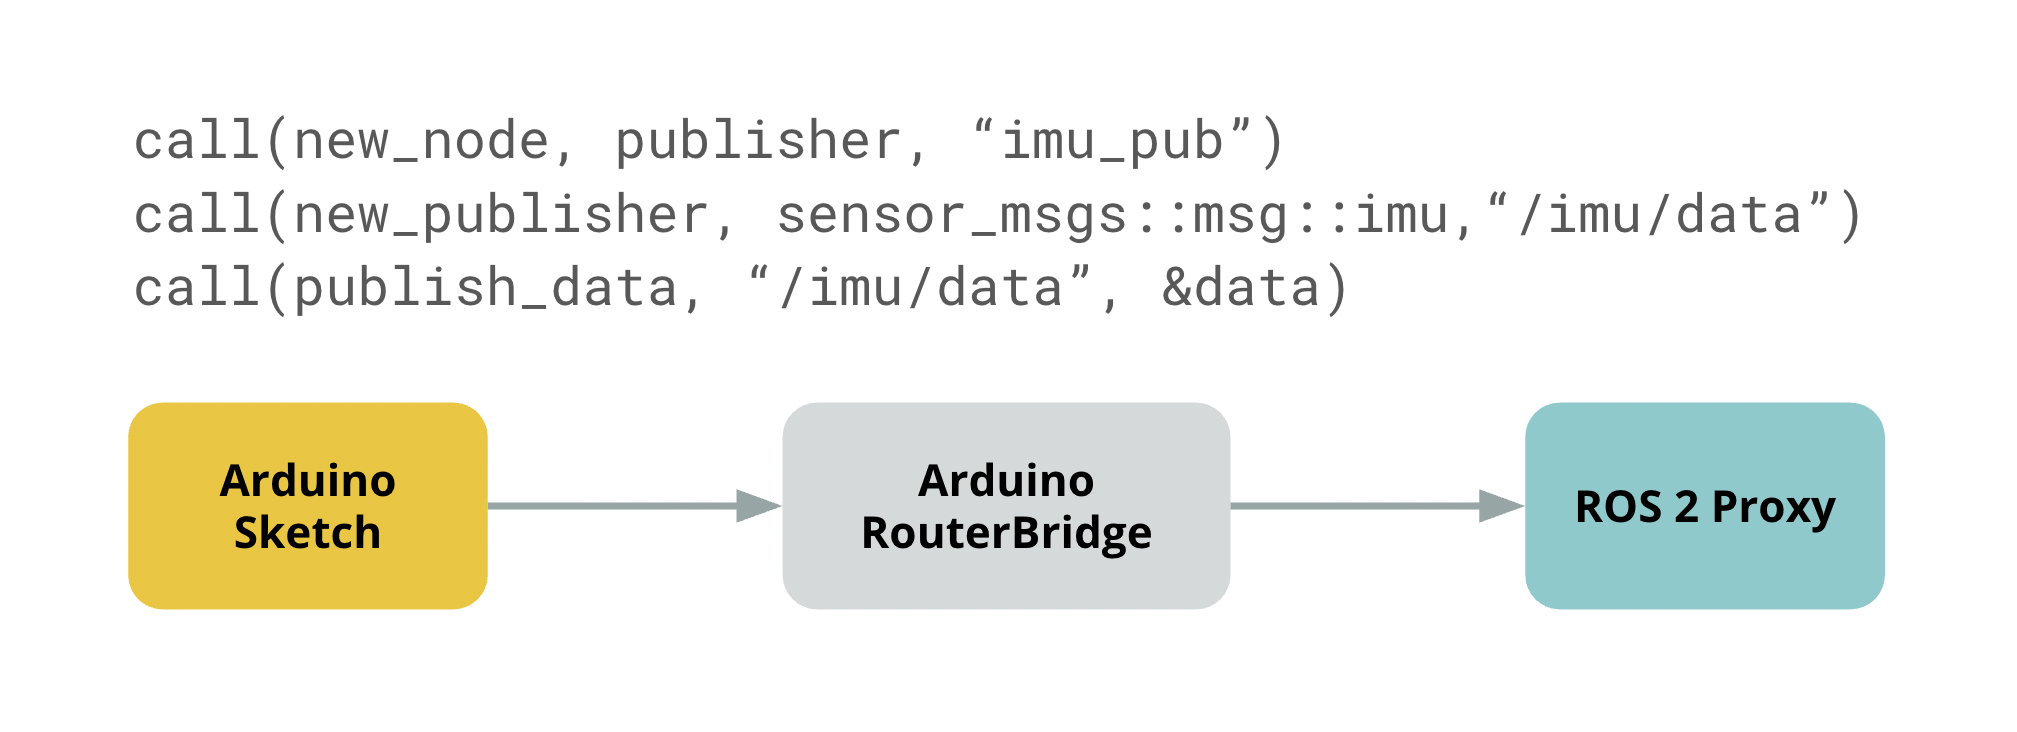
Getting those two worlds to talk to each other usually means wrestling with custom serial protocols, dedicated drivers, or heavy middleware wrappers. The Arduino® VENTUNO™ Q board was designed to make that boundary disappear.

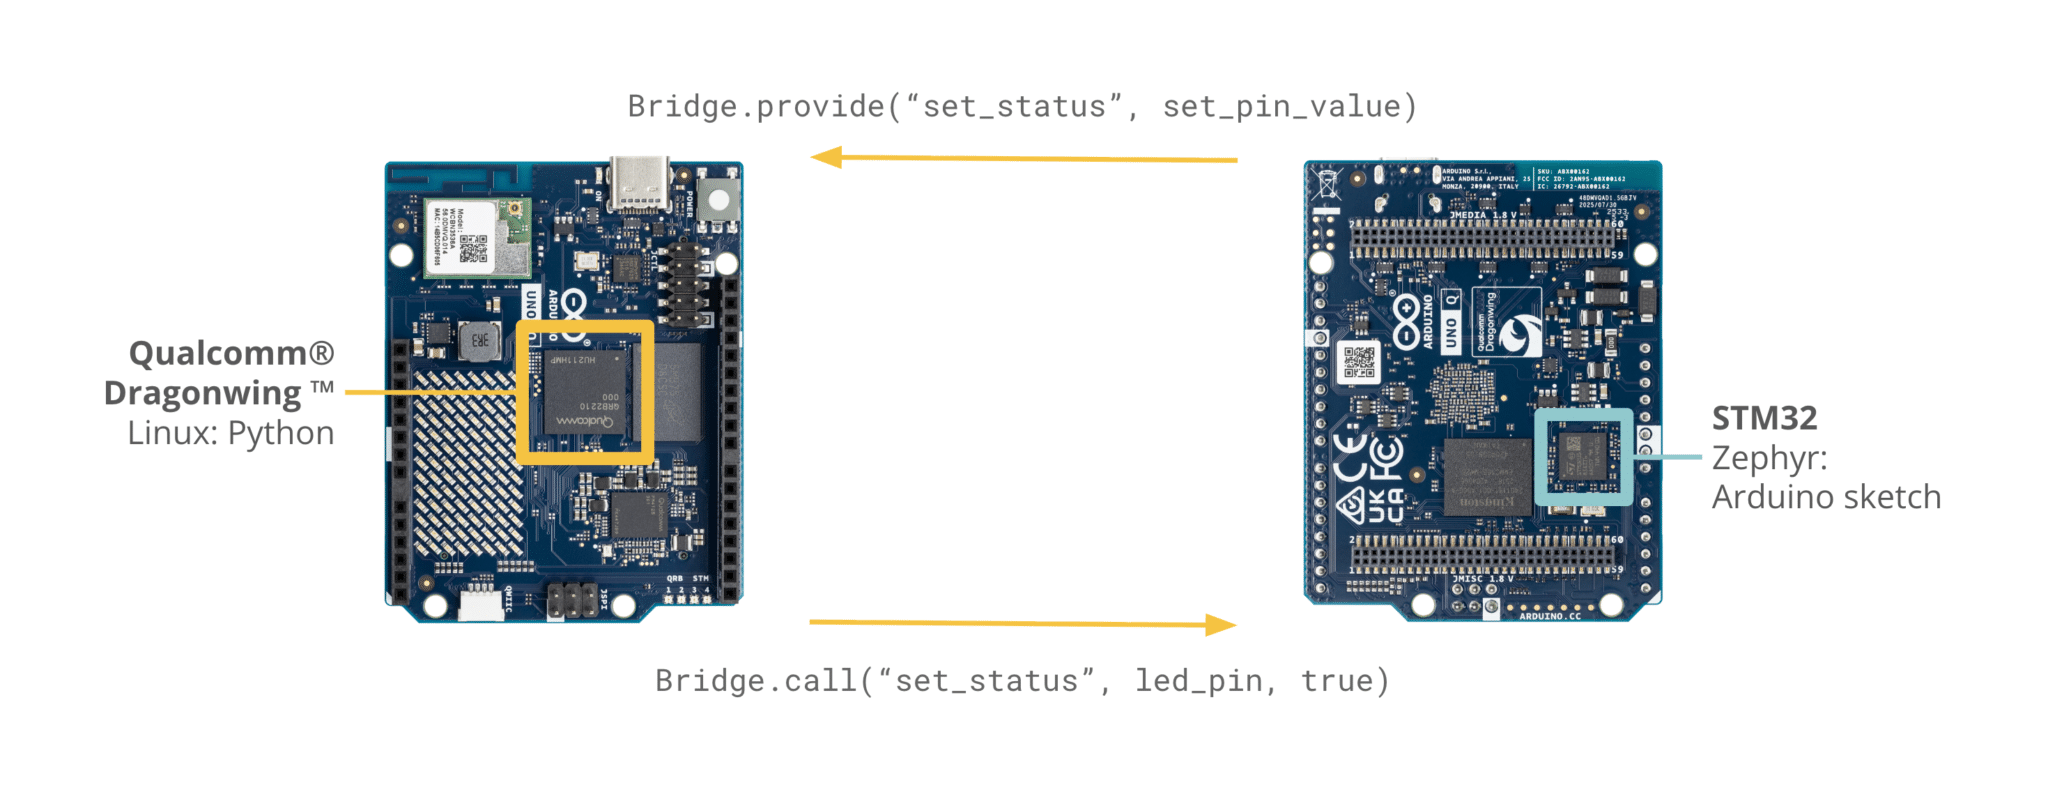
Because VENTUNO Q is structured to combine a Linux-capable MPU and a real-time microcontroller on the exact same board, you get a true dual-brain architecture.…

Continue reading — create a free account

Join HashtagPLUS to read full articles, follow hashtags, vote, and join the conversation.