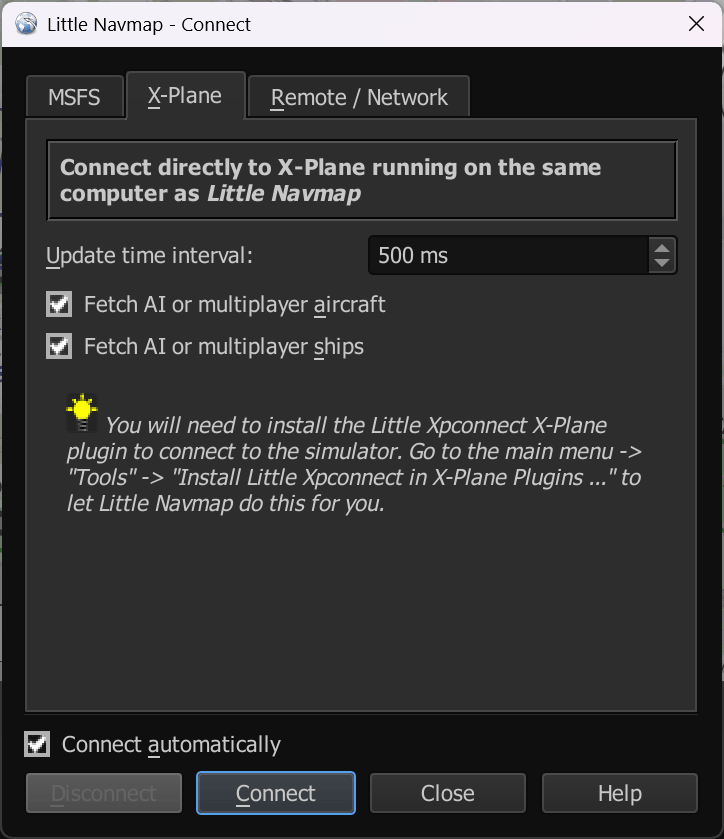
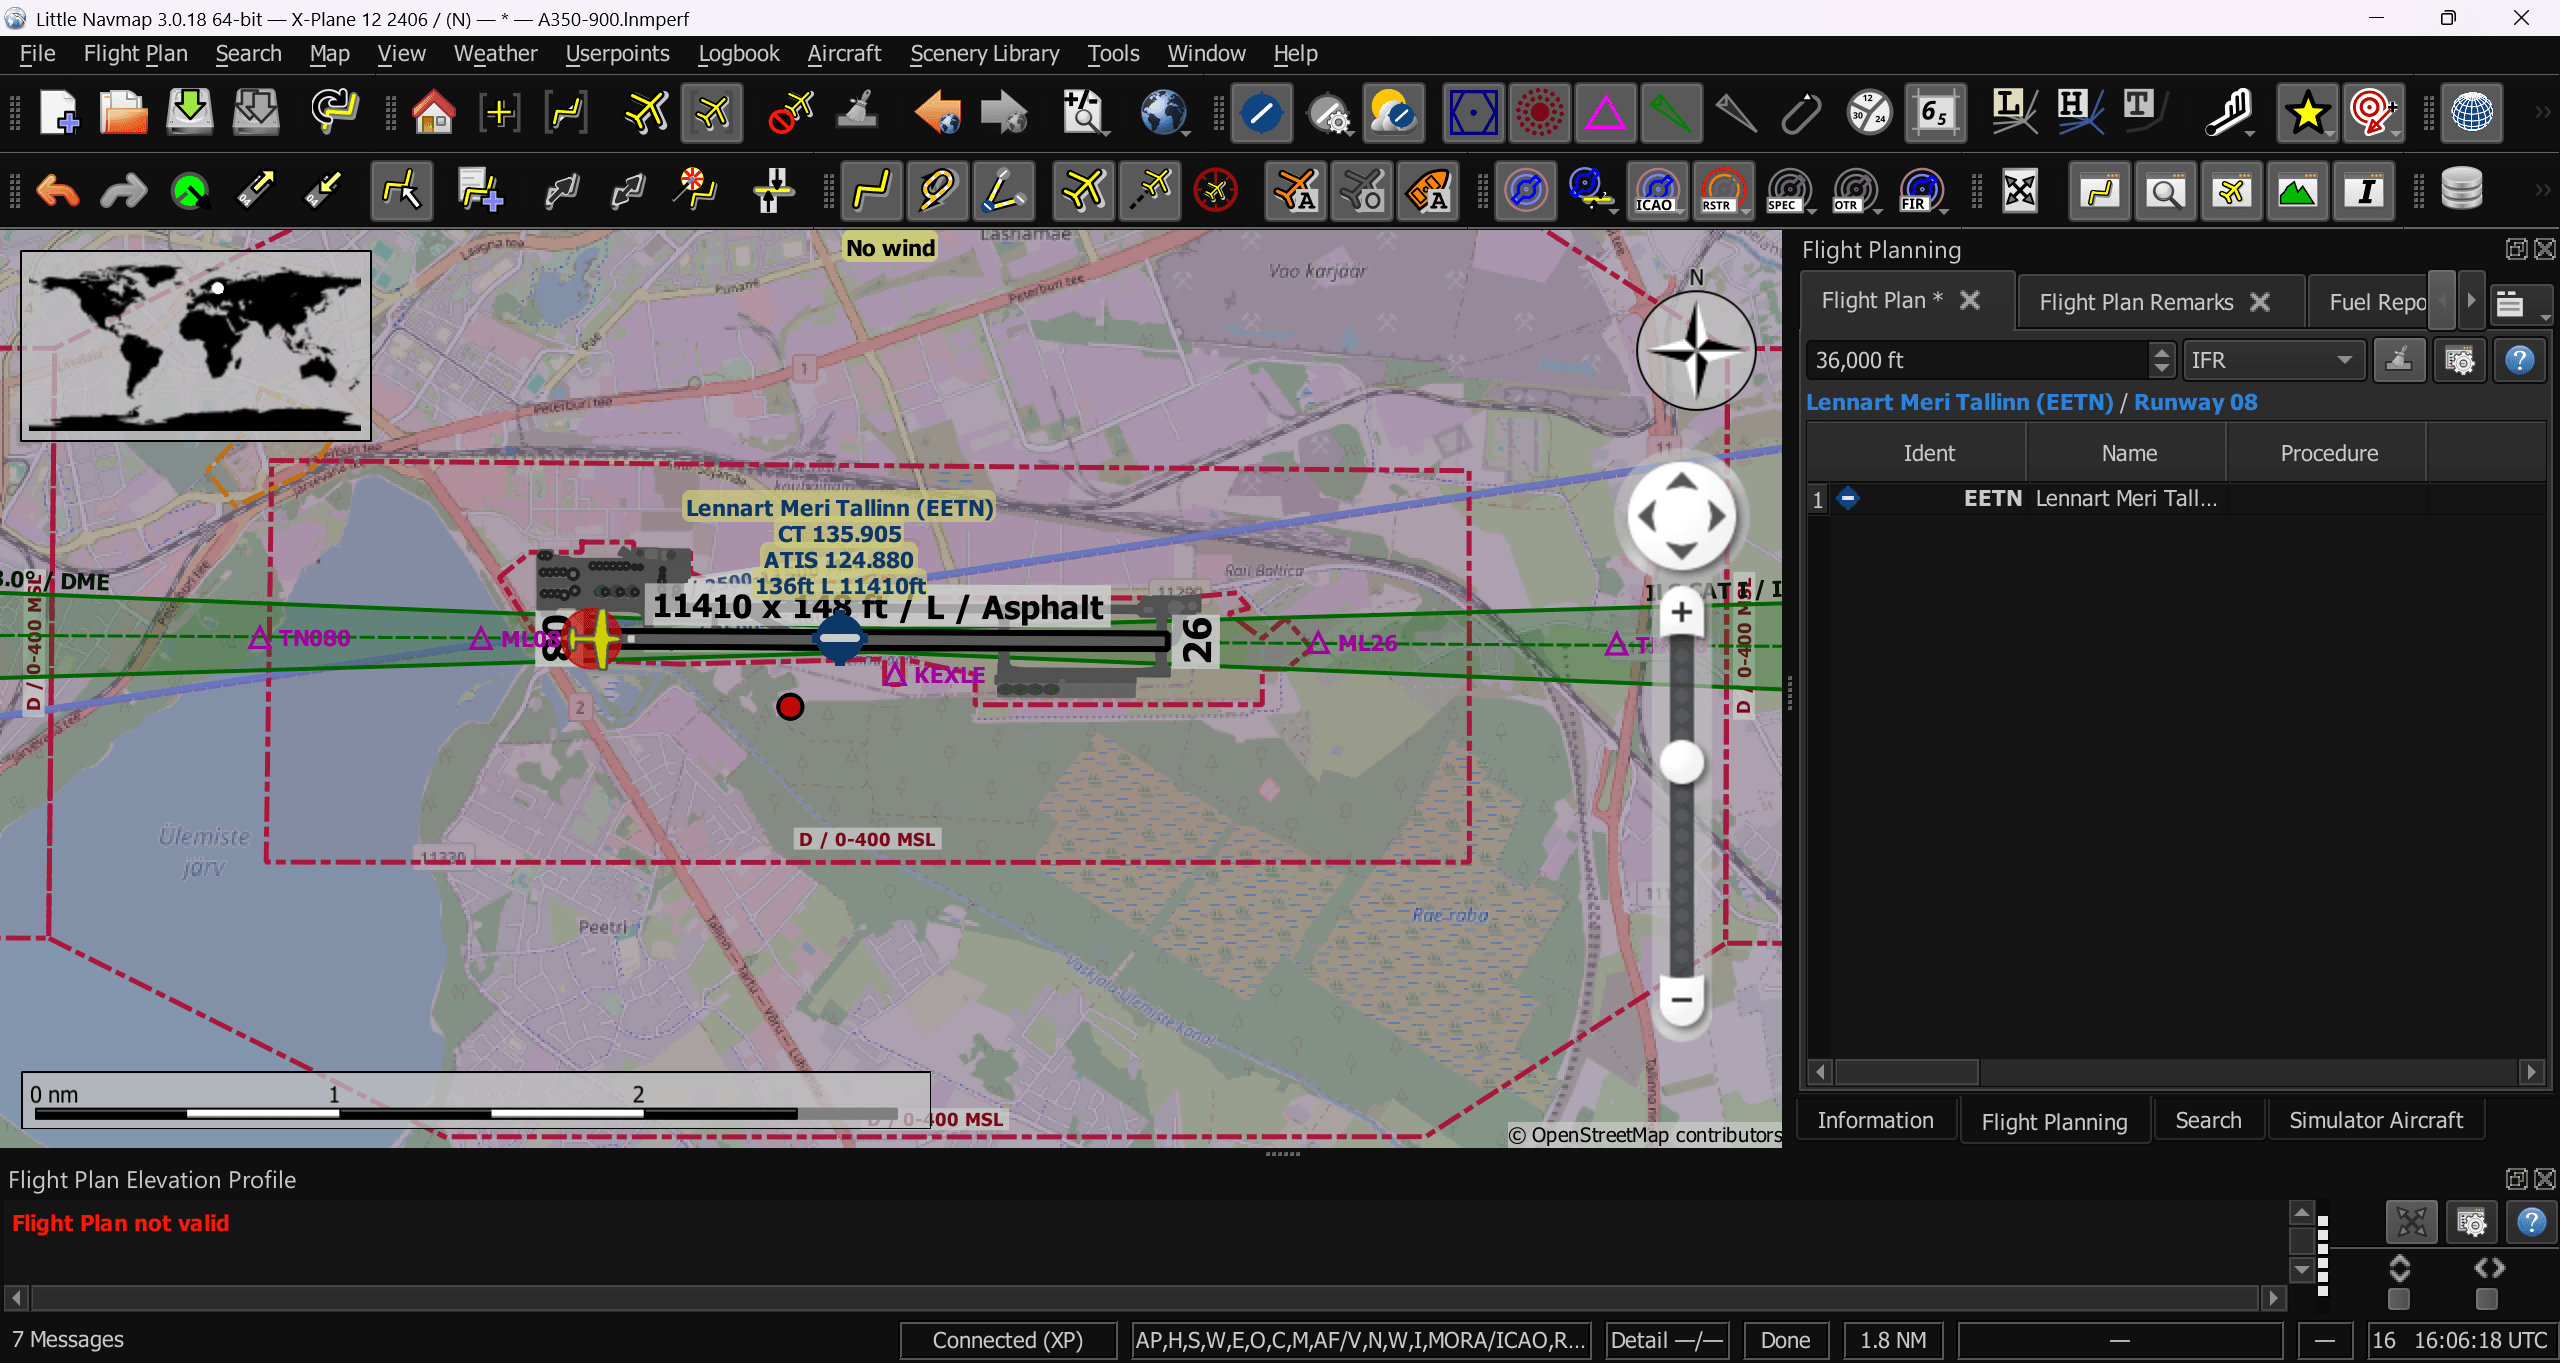
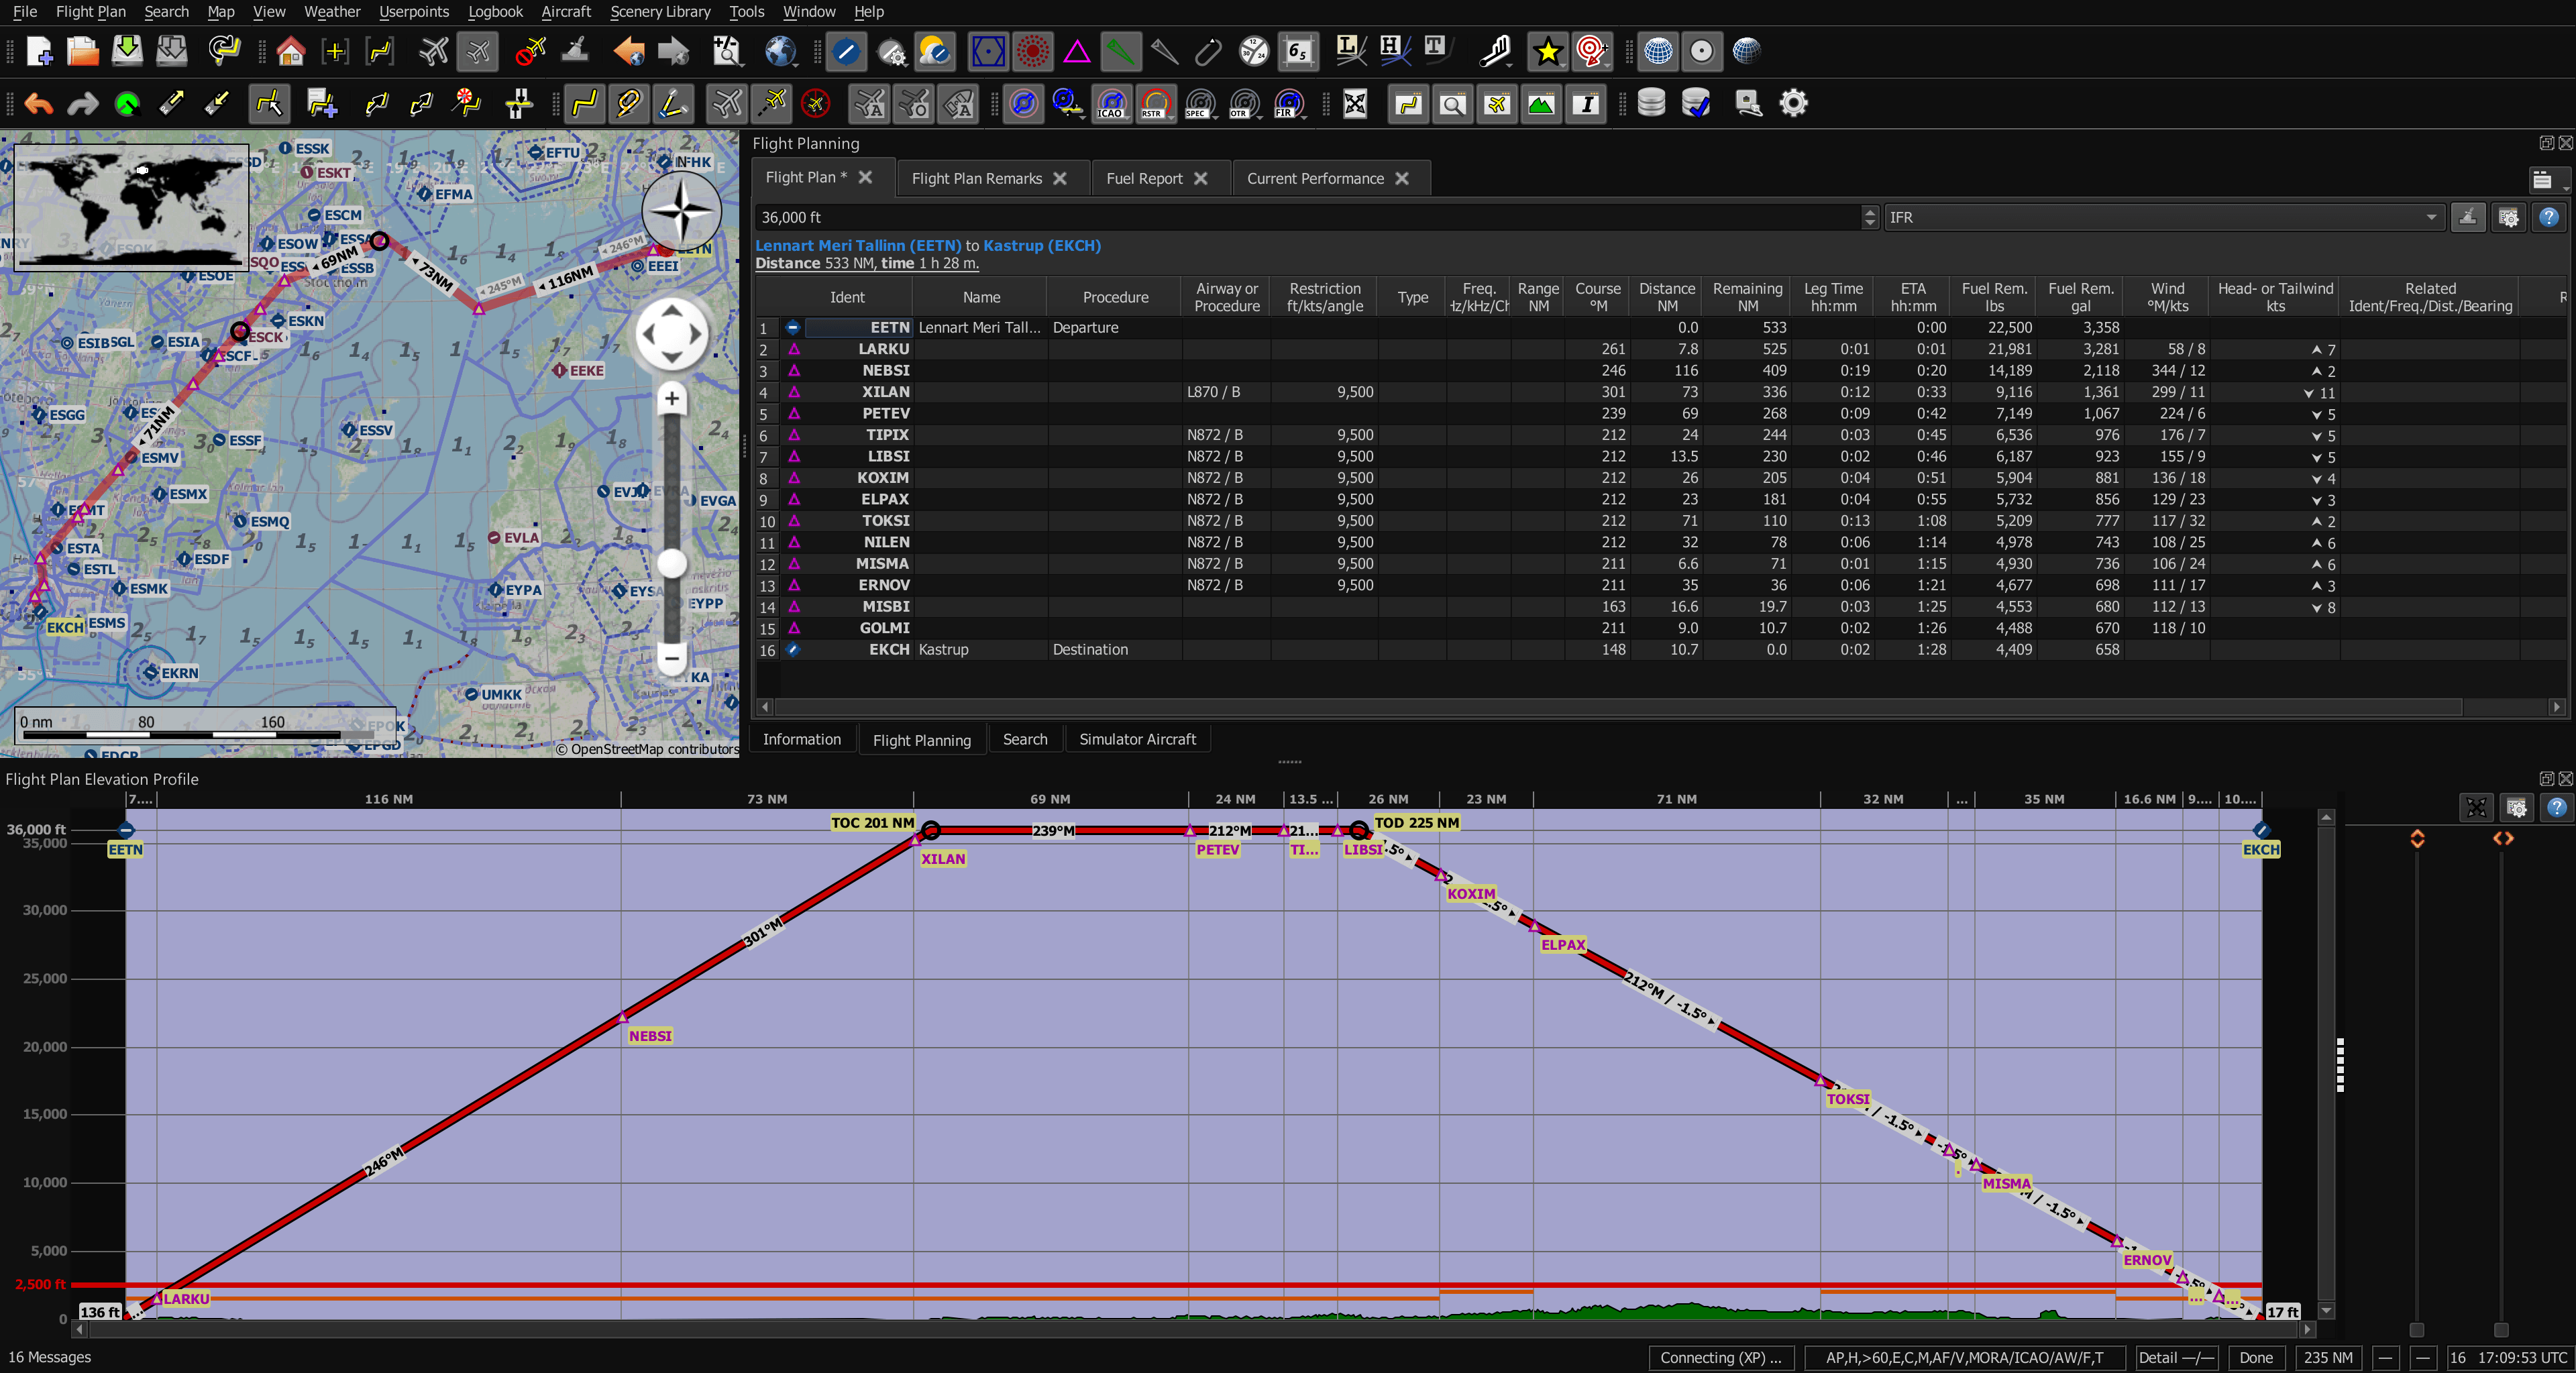
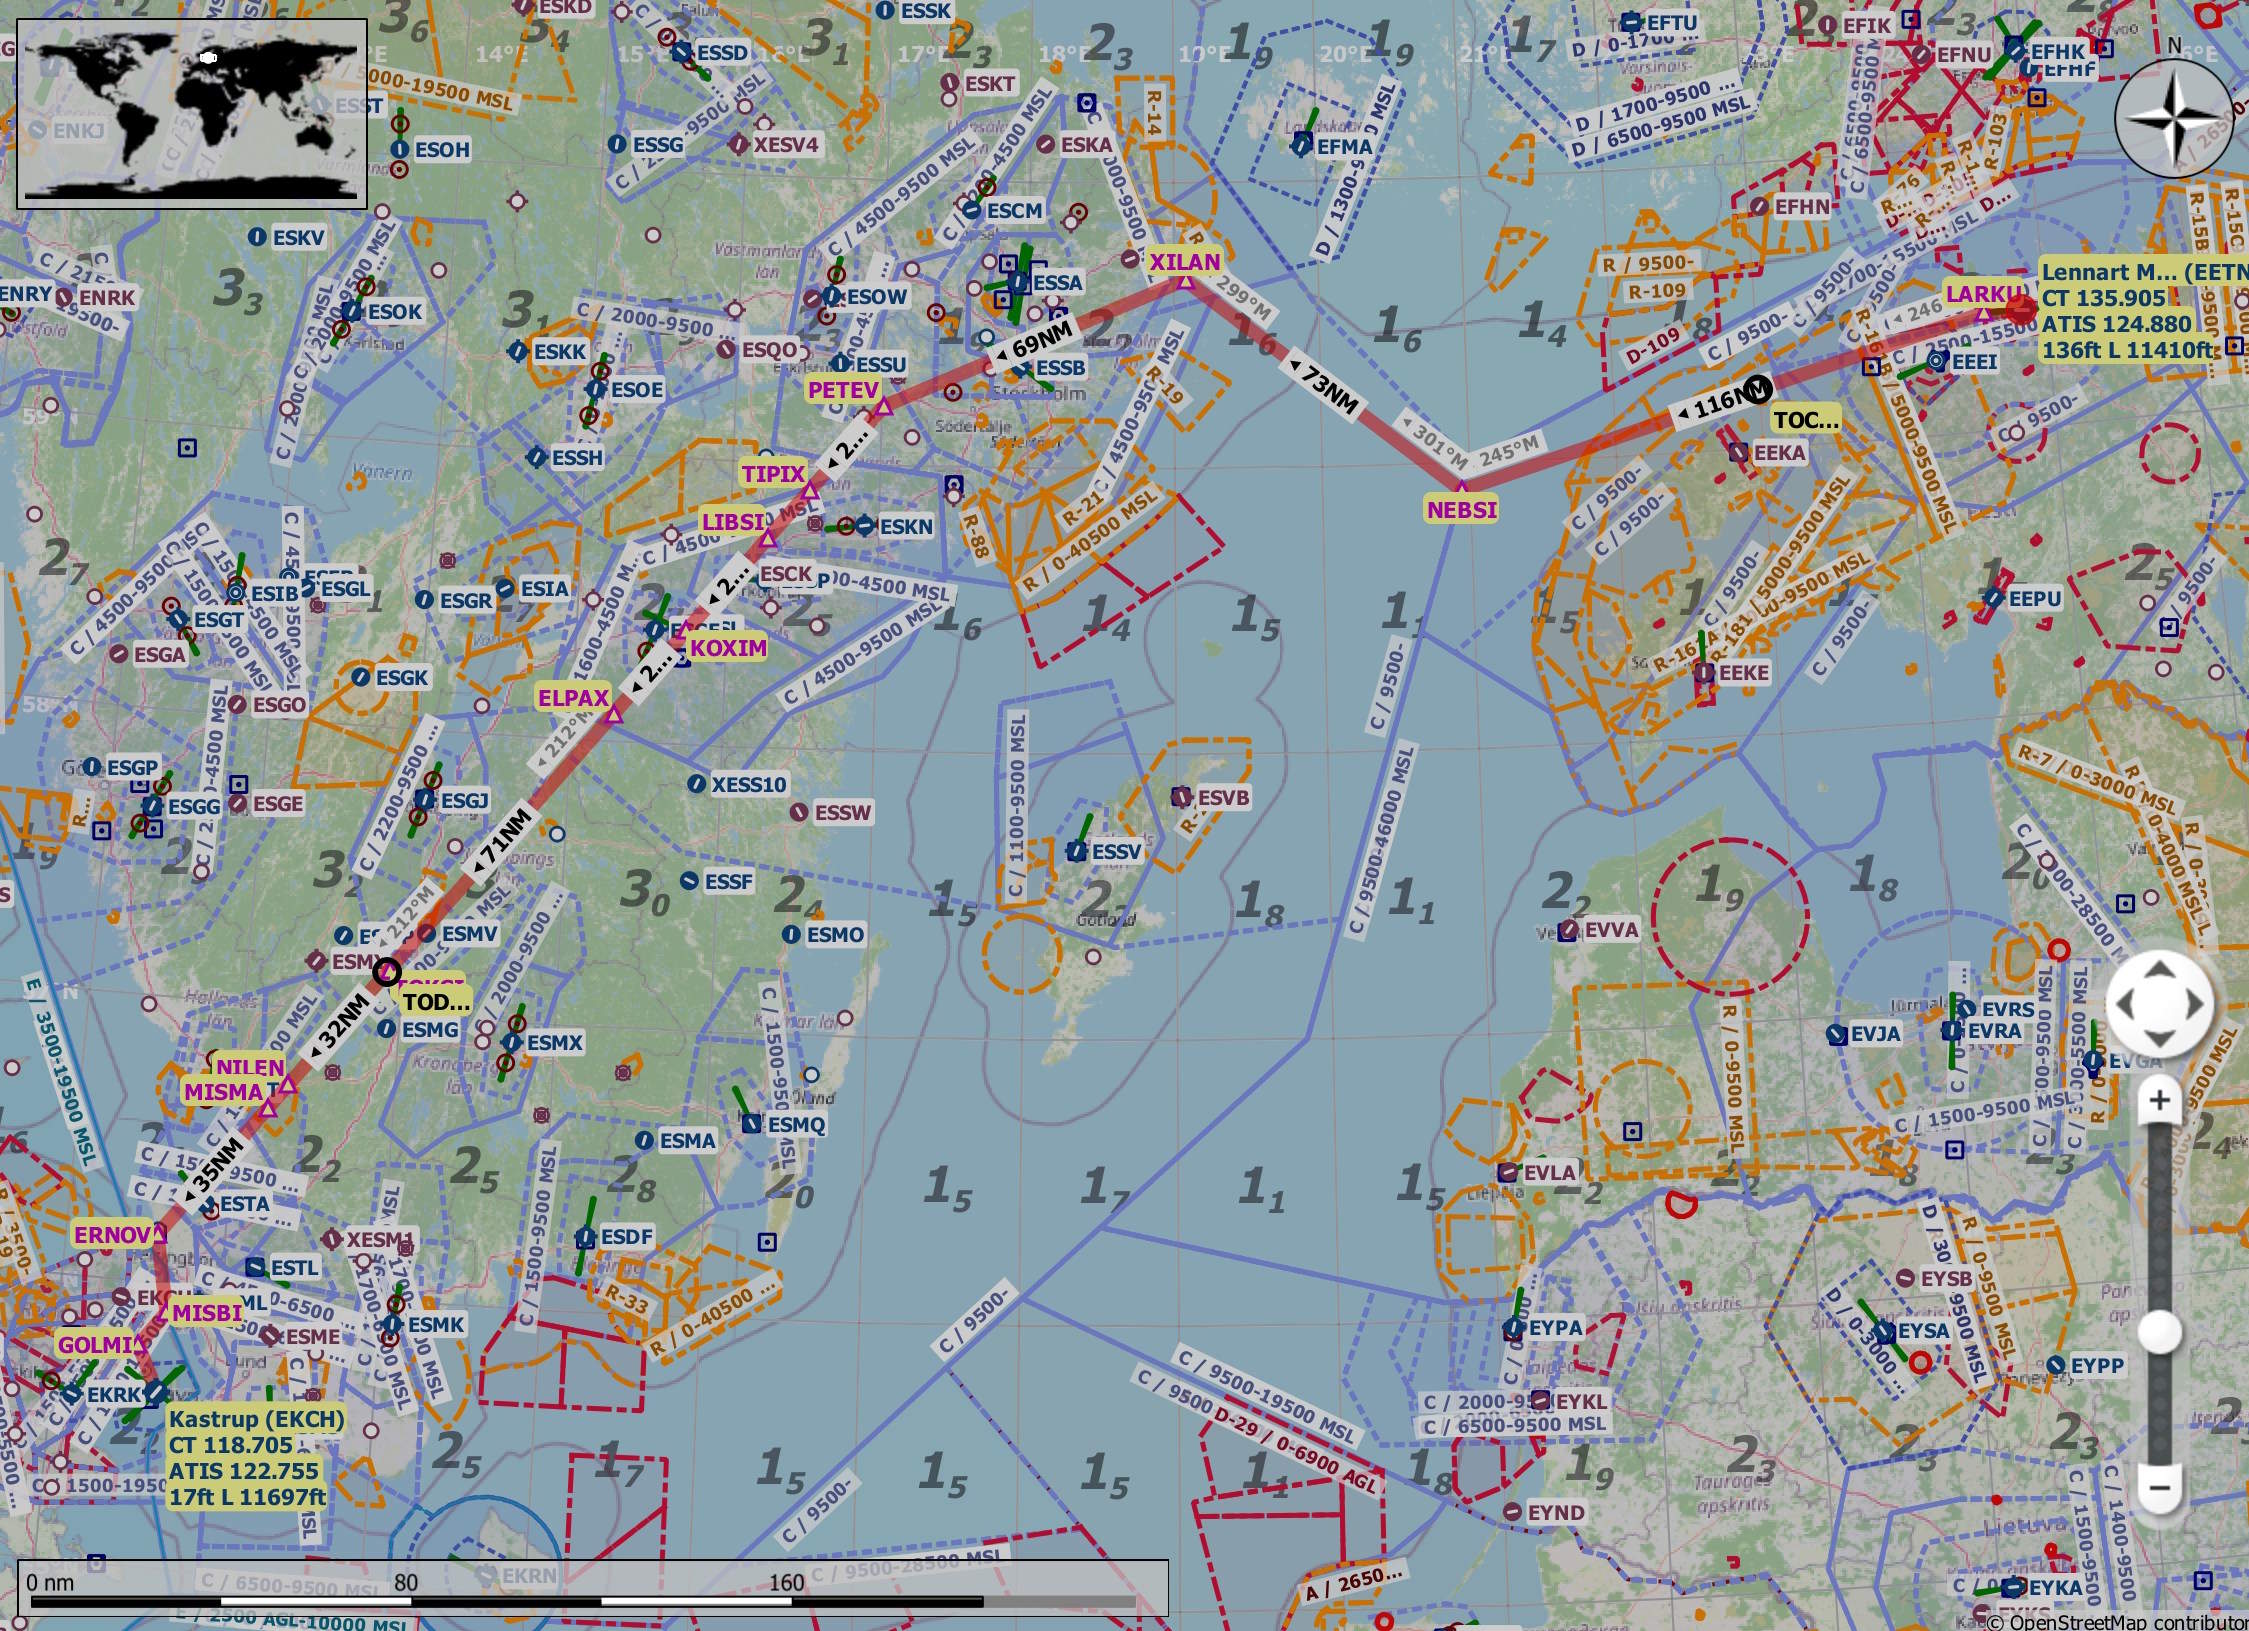
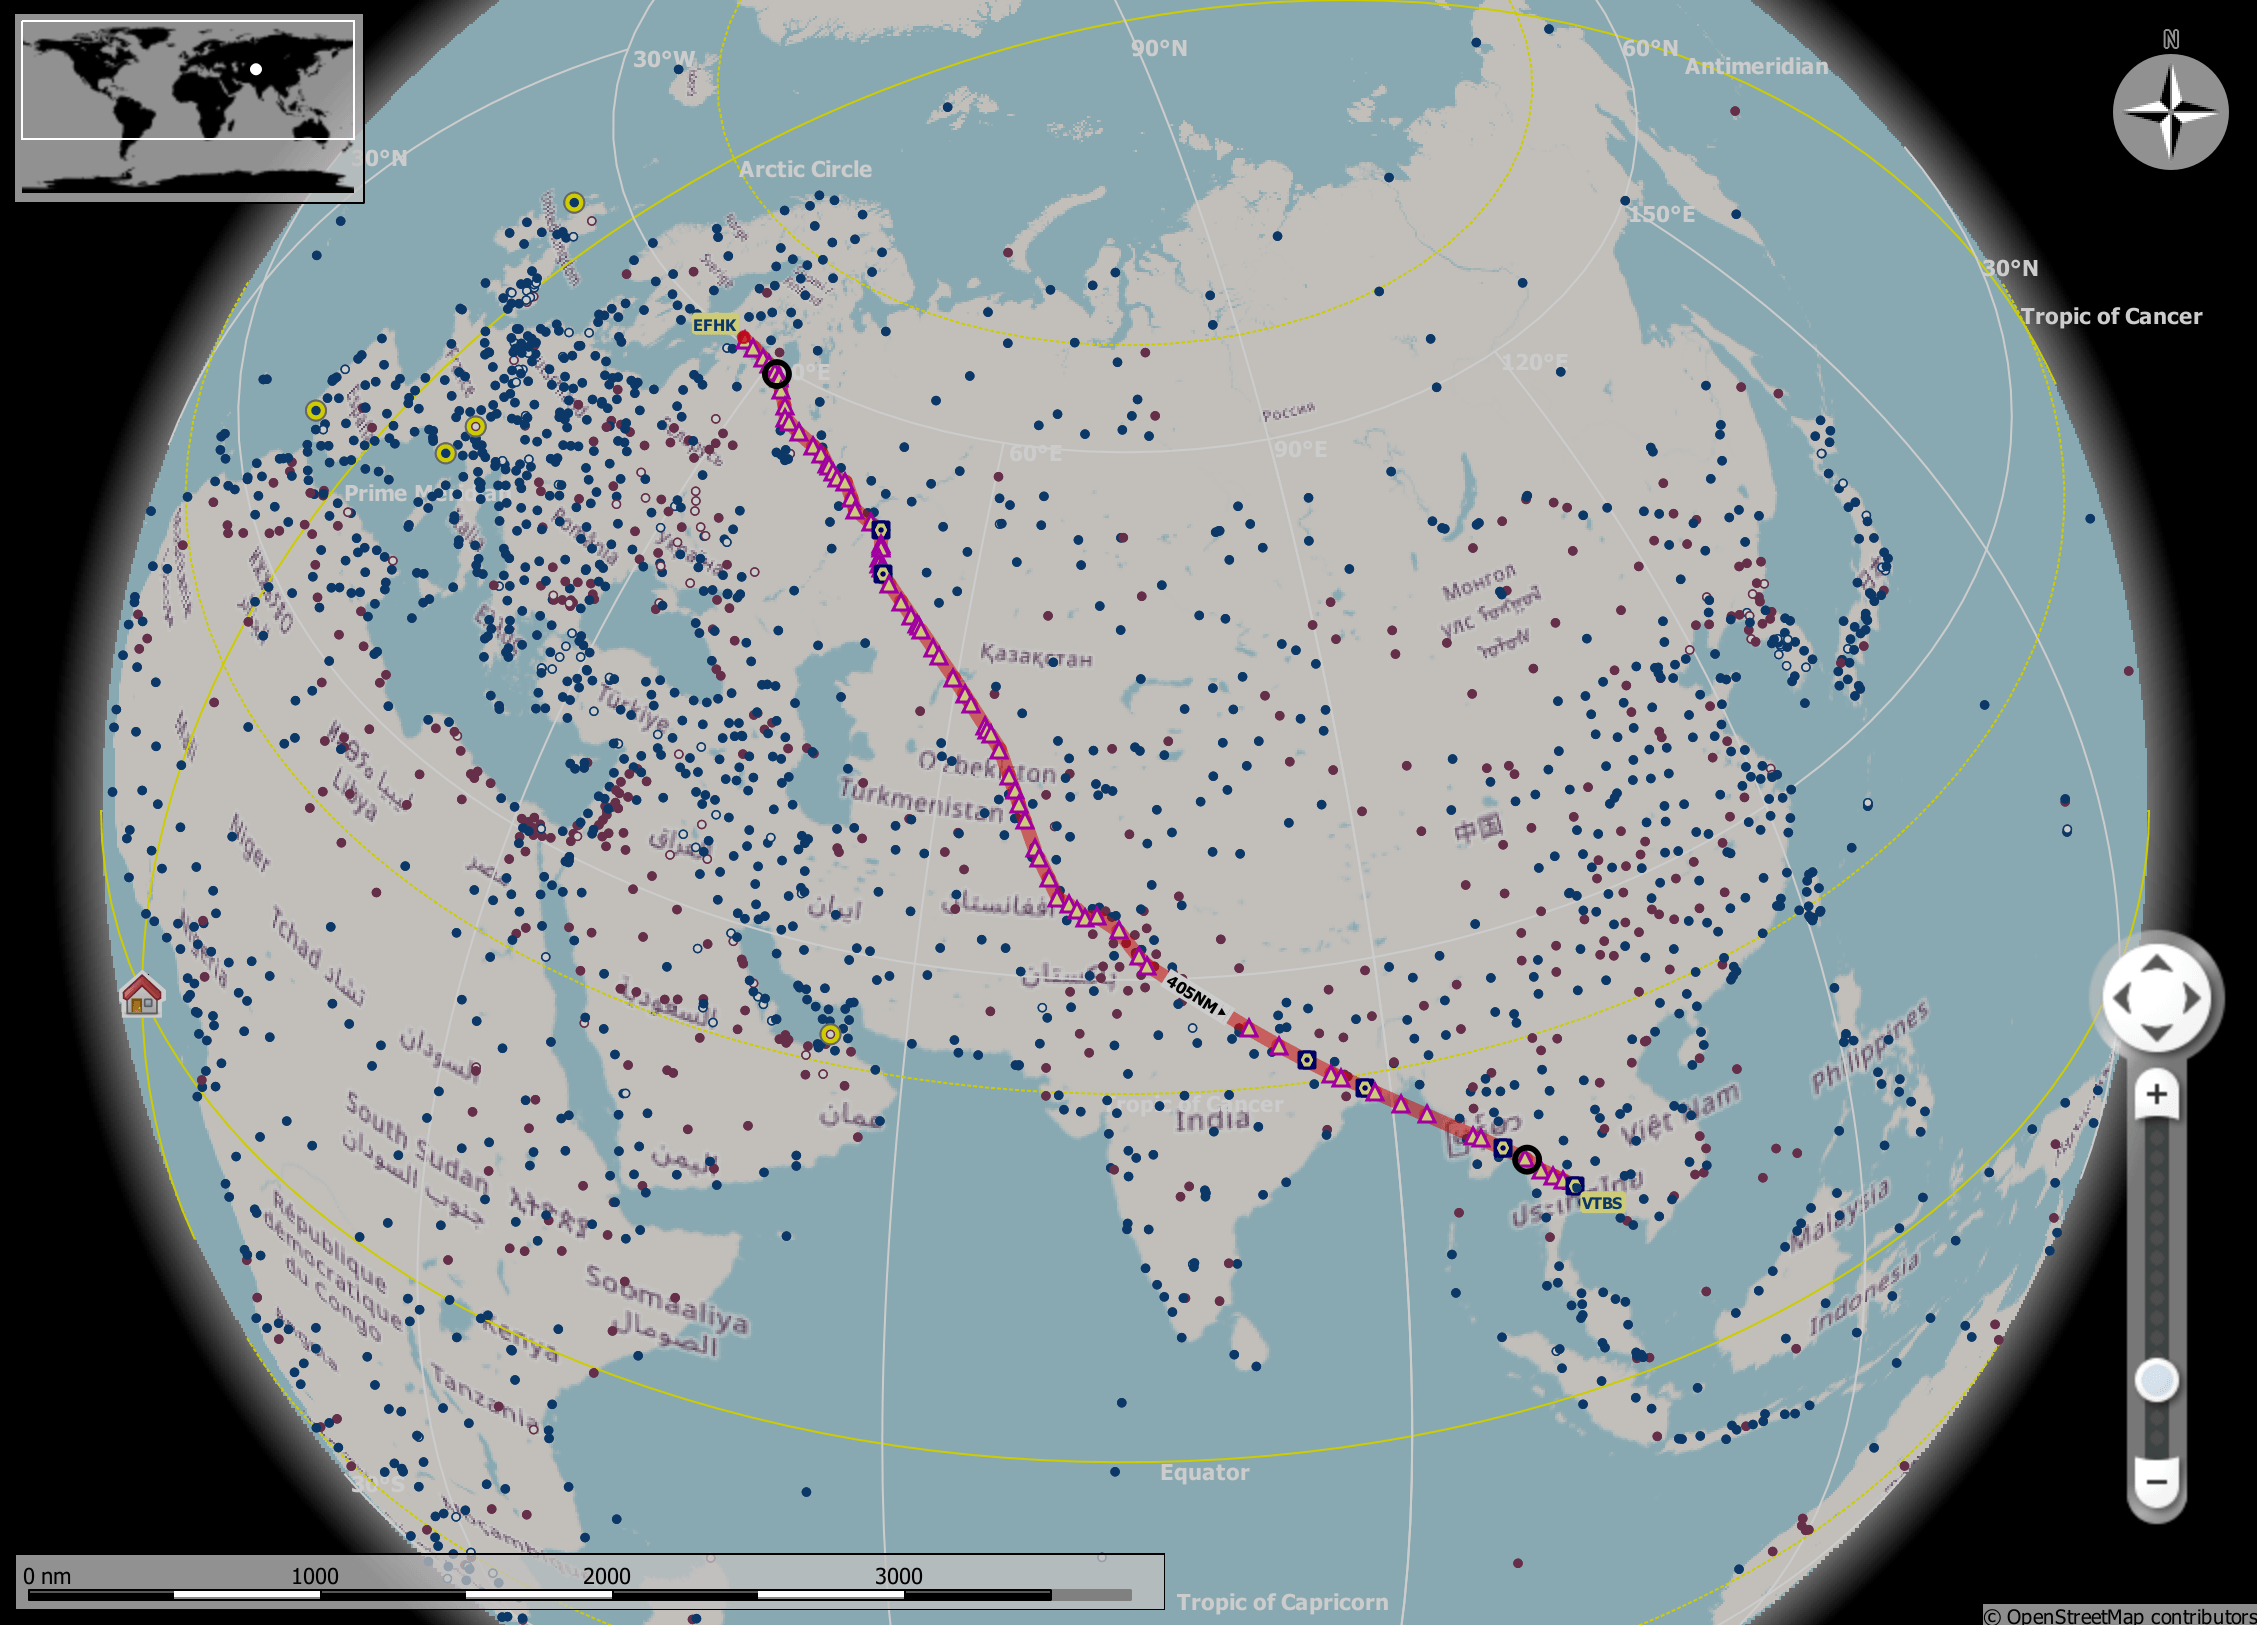
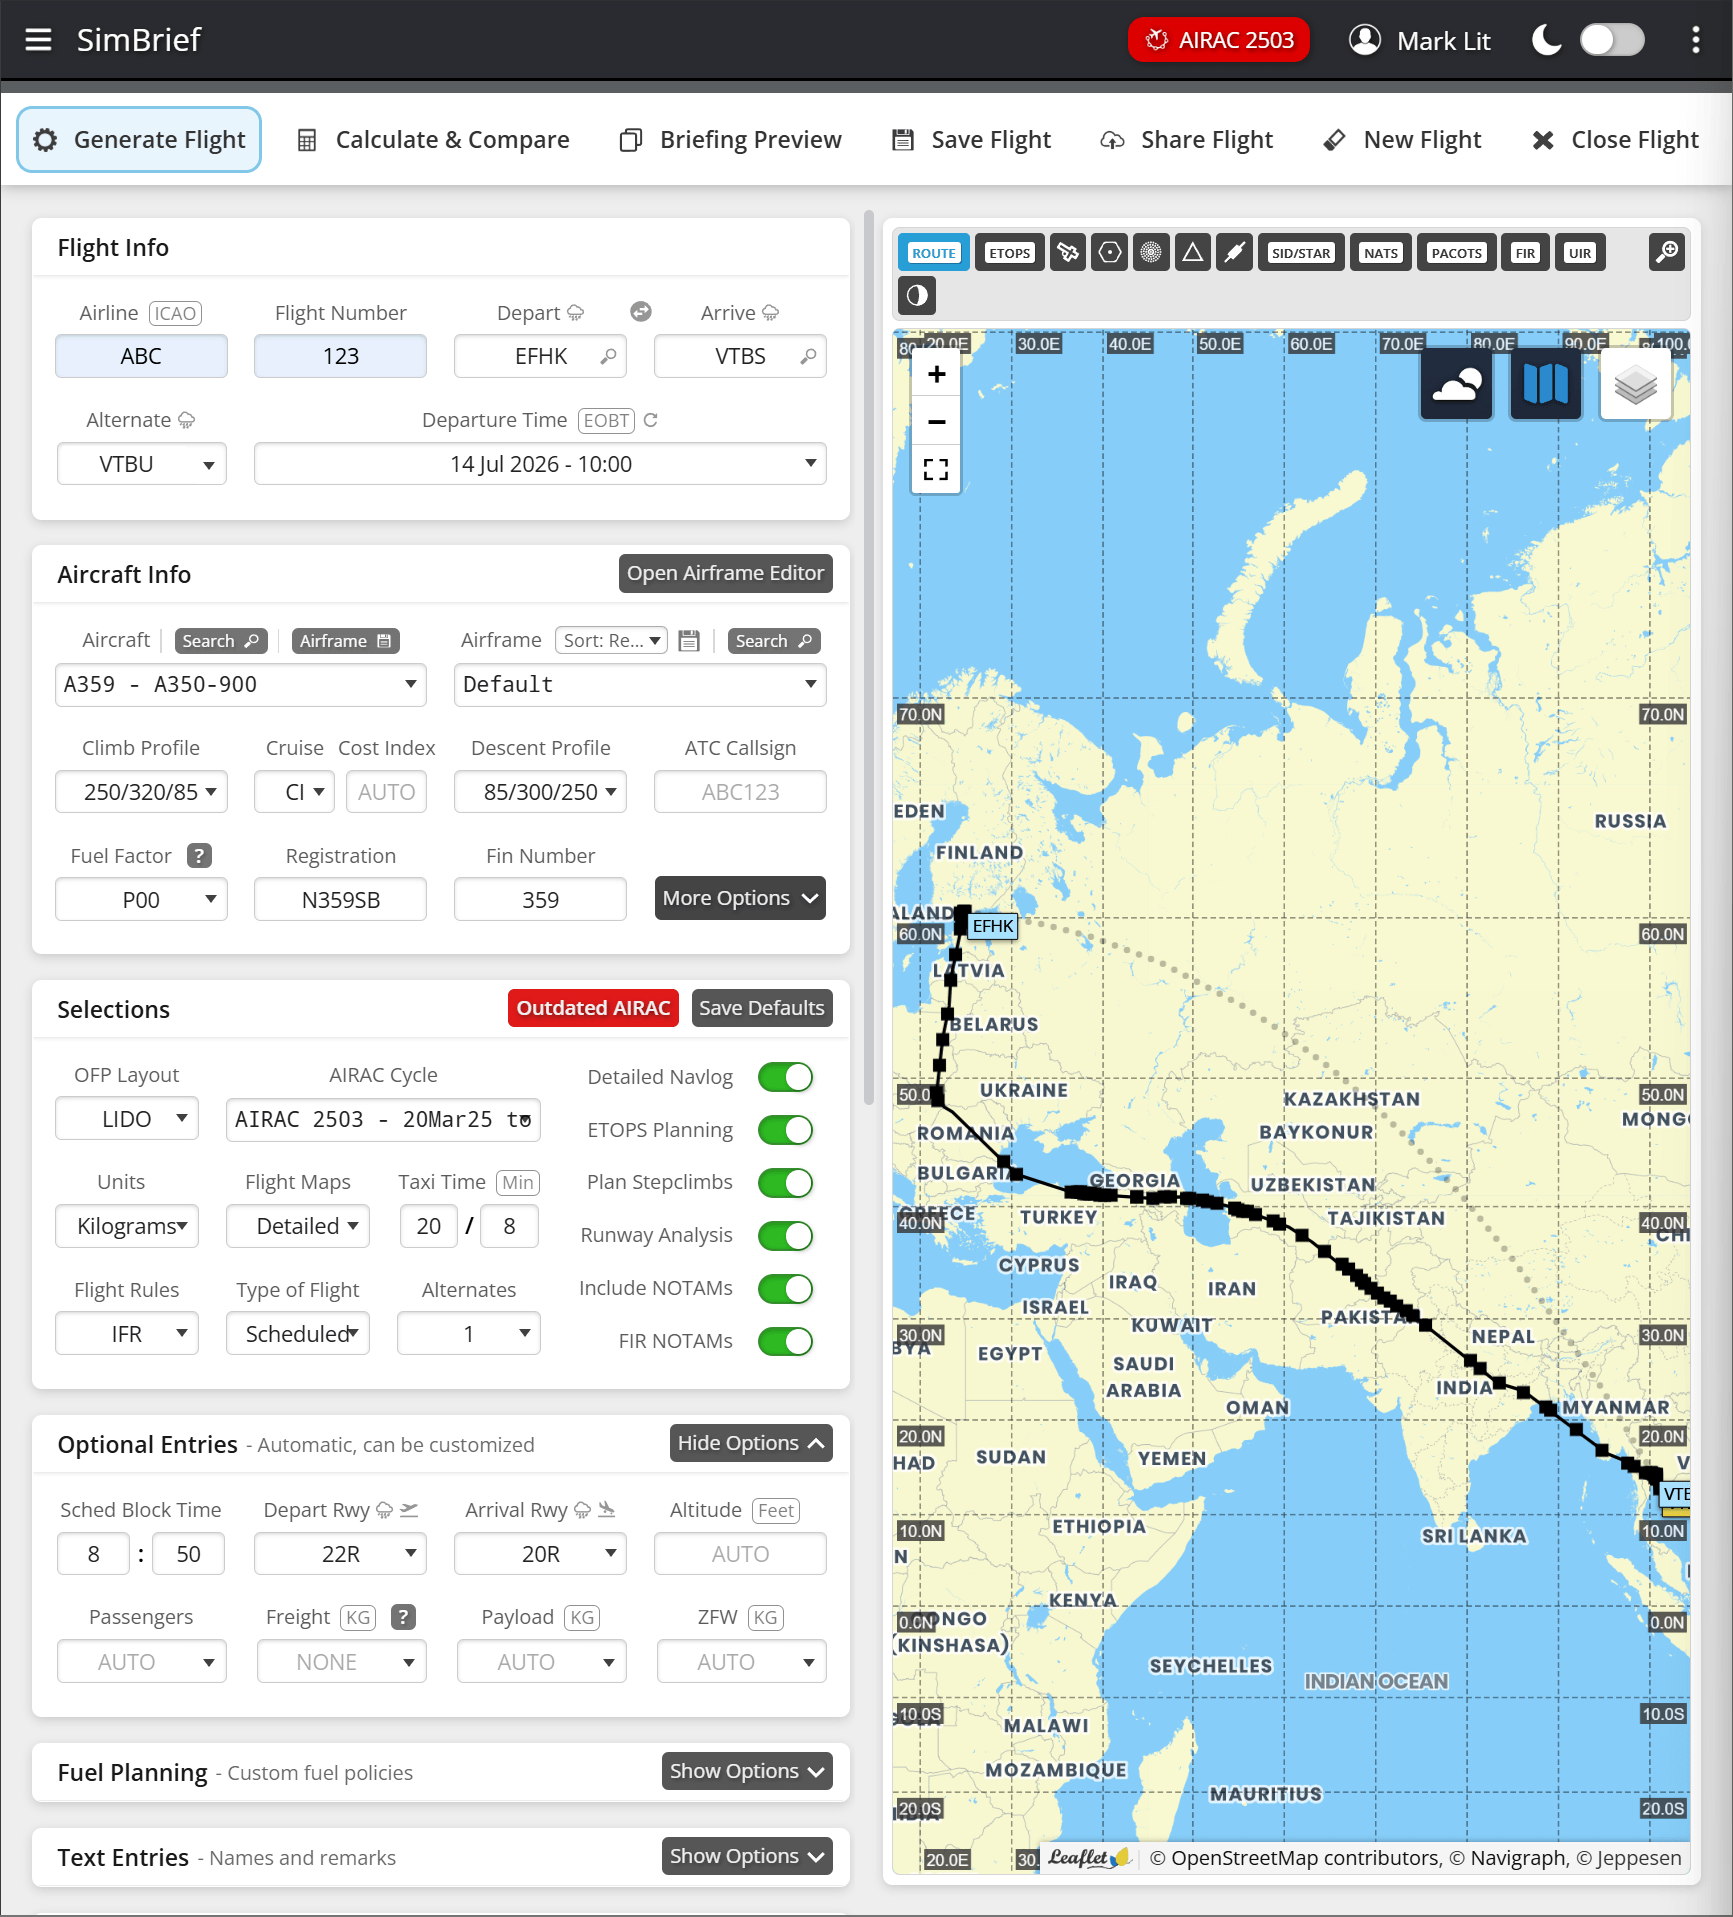
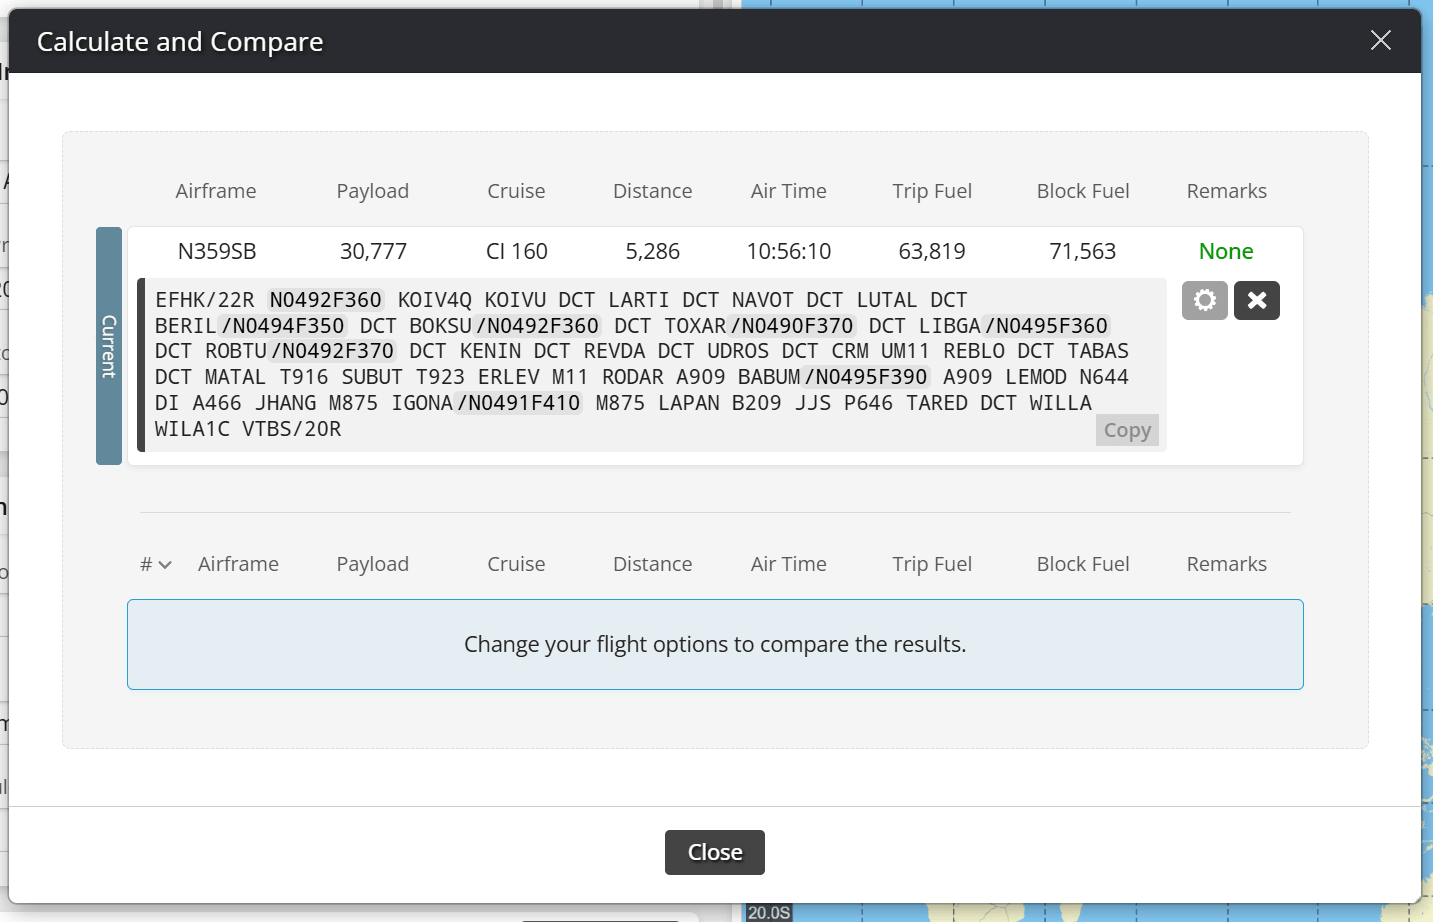
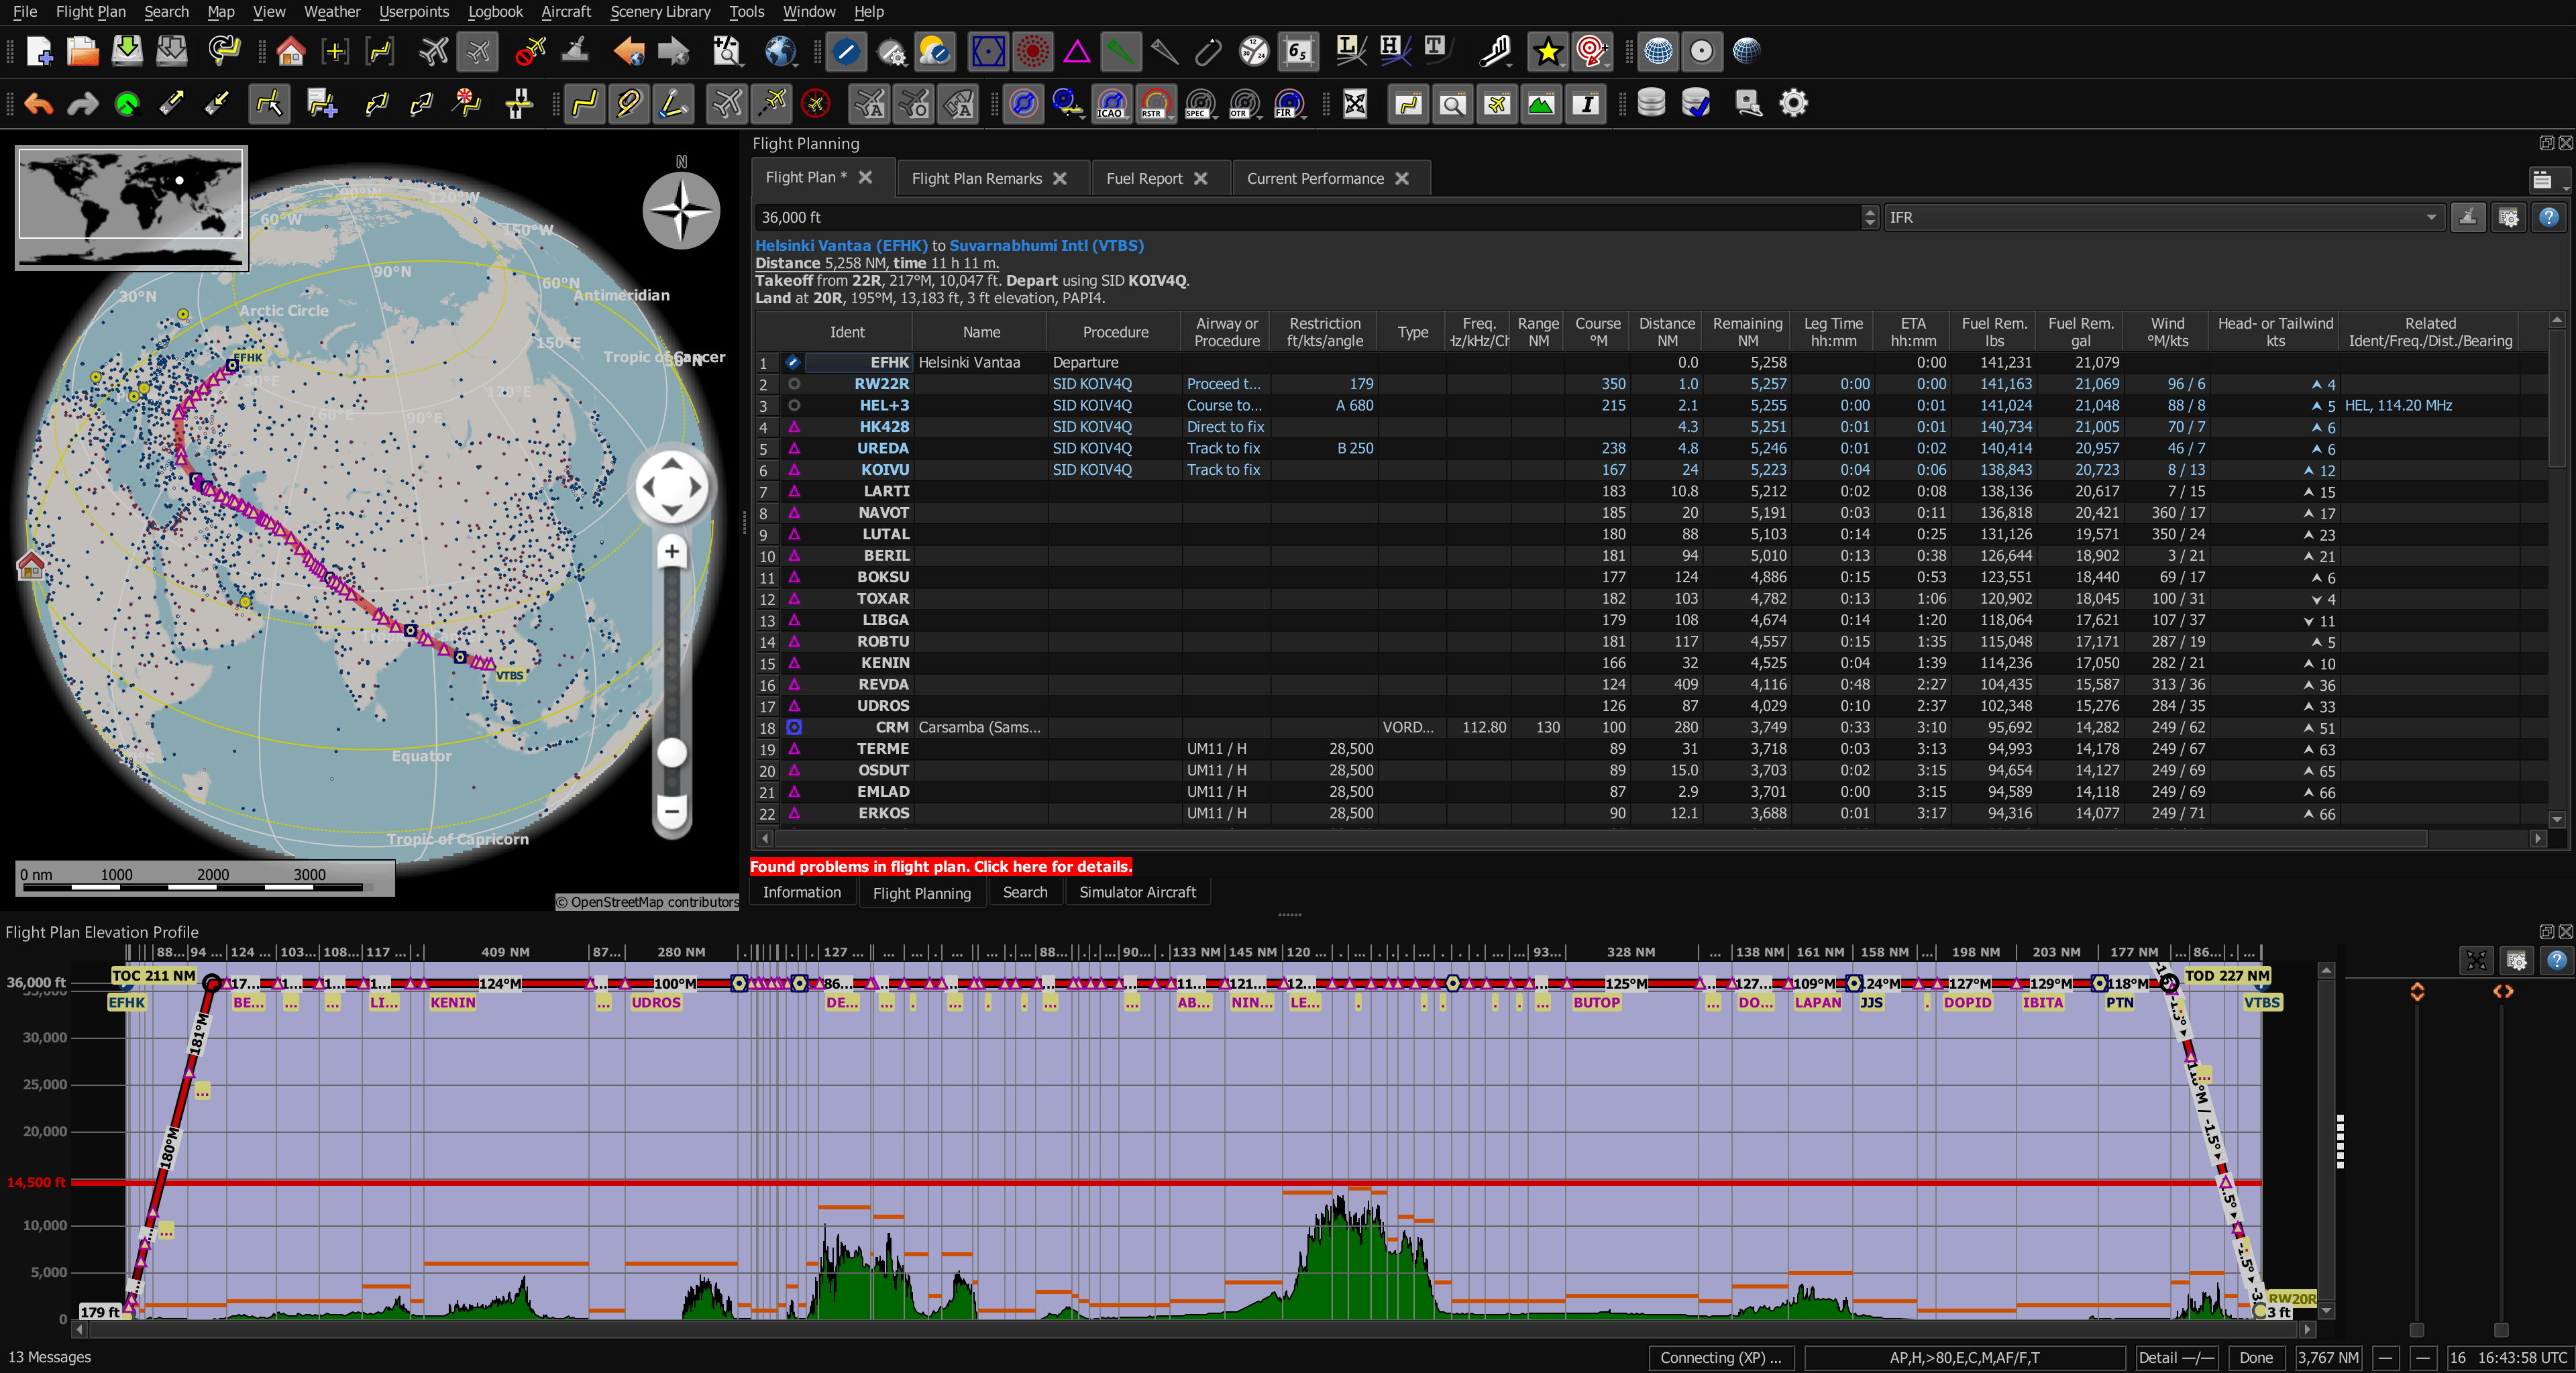
Little Navmap is an open source flight planner. It supports working with flight simulators like X-Plane and Microsoft Flight Simulator. The project was started ten years ago by Alexander Barthel. It is made up of ~120K lines of C++. It uses Qt5, OpenGL and D3D for rendering the UI. The 367 MB installation footprint includes a 134 MB SQLite3 database where its data is kept. The application reminds me of QGIS, which has a code base that is an order of magnitude larger. Little Navmap only needs 14K lines of C++ for routing; the main UI is ~7K lines; the map display and interaction lean heavily on KDE's Marble , so only 21K lines are needed and weather support only needs 2K lines of code. At the time of this writing, there are only 119 open issues and 992 closed ones on GitHub . In this post, I'll walk through planning two flights with Little Navmap. My Workstation I'm using a 5.7 GHz AMD Ryzen 9 9950X CPU. It has 16 cores and 32 threads and 1.2 MB of L1, 16 MB of L2 and 64 MB of L3 cache.…