Skip to content
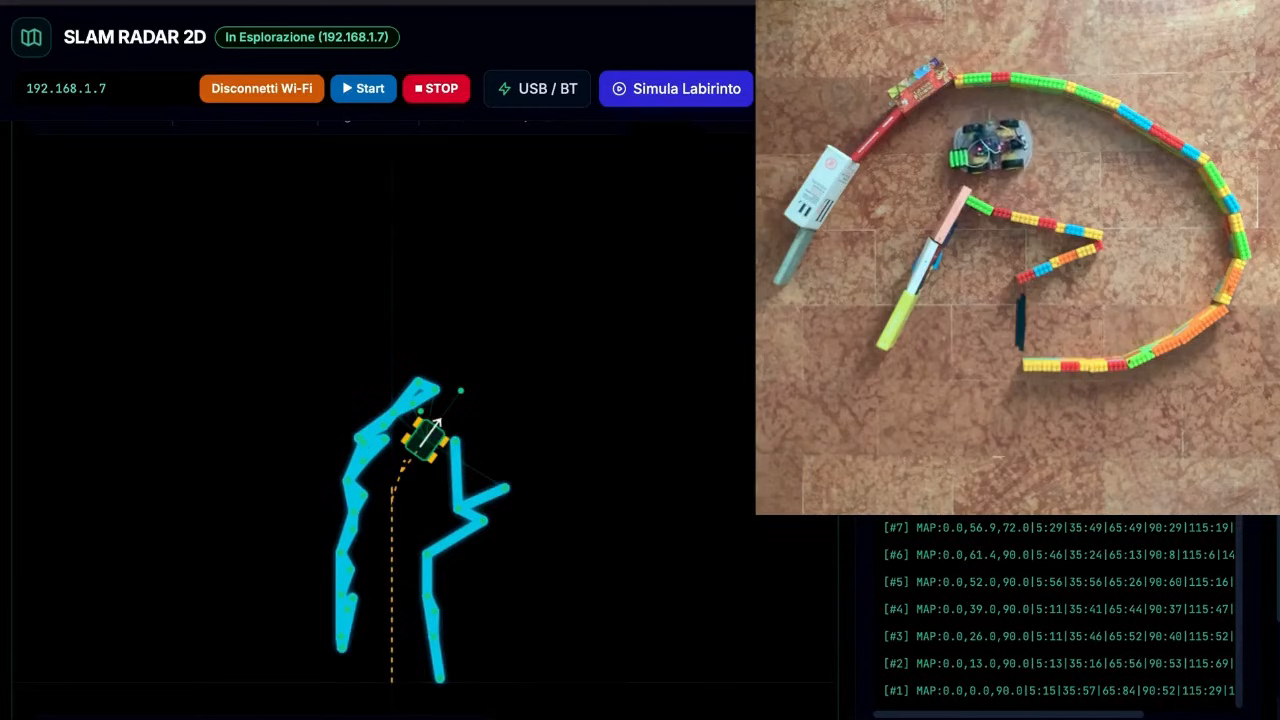
There are plenty of “robot” projects out there that are really just a small remote control platform of some sort. We often like to think of robots of having some sort of autonomy though. [Luca Fagioli] demonstrates a great example of this with his explorer robot that uses Simultaneous Localization and Mapping (SLAM) to navigate its environment.
The robot is a built on a small plastic chassis, with one gear motor per drive wheel. Running the show is an Arduino Uno R4 Wi-Fi, paired with the Sensor Shield 5.0 and an L298N motor driver board. There’s also an HC-SR04 ultrasonic sensor module onboard, mounted atop an SG-90 servo motor so it can be panned around. The ultrasonic sensor determines the range between the robot and surrounding walls, and a map is constructed at the same time as the robot is localizing itself within it.…